
Jetbot Tools with YOLOv11 Vision Detection and NanoLLM Container for NAV2 ROS2 Robot — Version 2.1
Jetbot Tools is a collection of ROS2 nodes that integrate a YOLO‑based vision system and the Jetson NanoLLM Docker container for NVIDIA Jetson Orin platforms. With Jetbot Tools, you can build a cost‑effective two‑wheel robot equipped with a depth camera and a lidar sensor, enabling it to perform the following impressive tasks
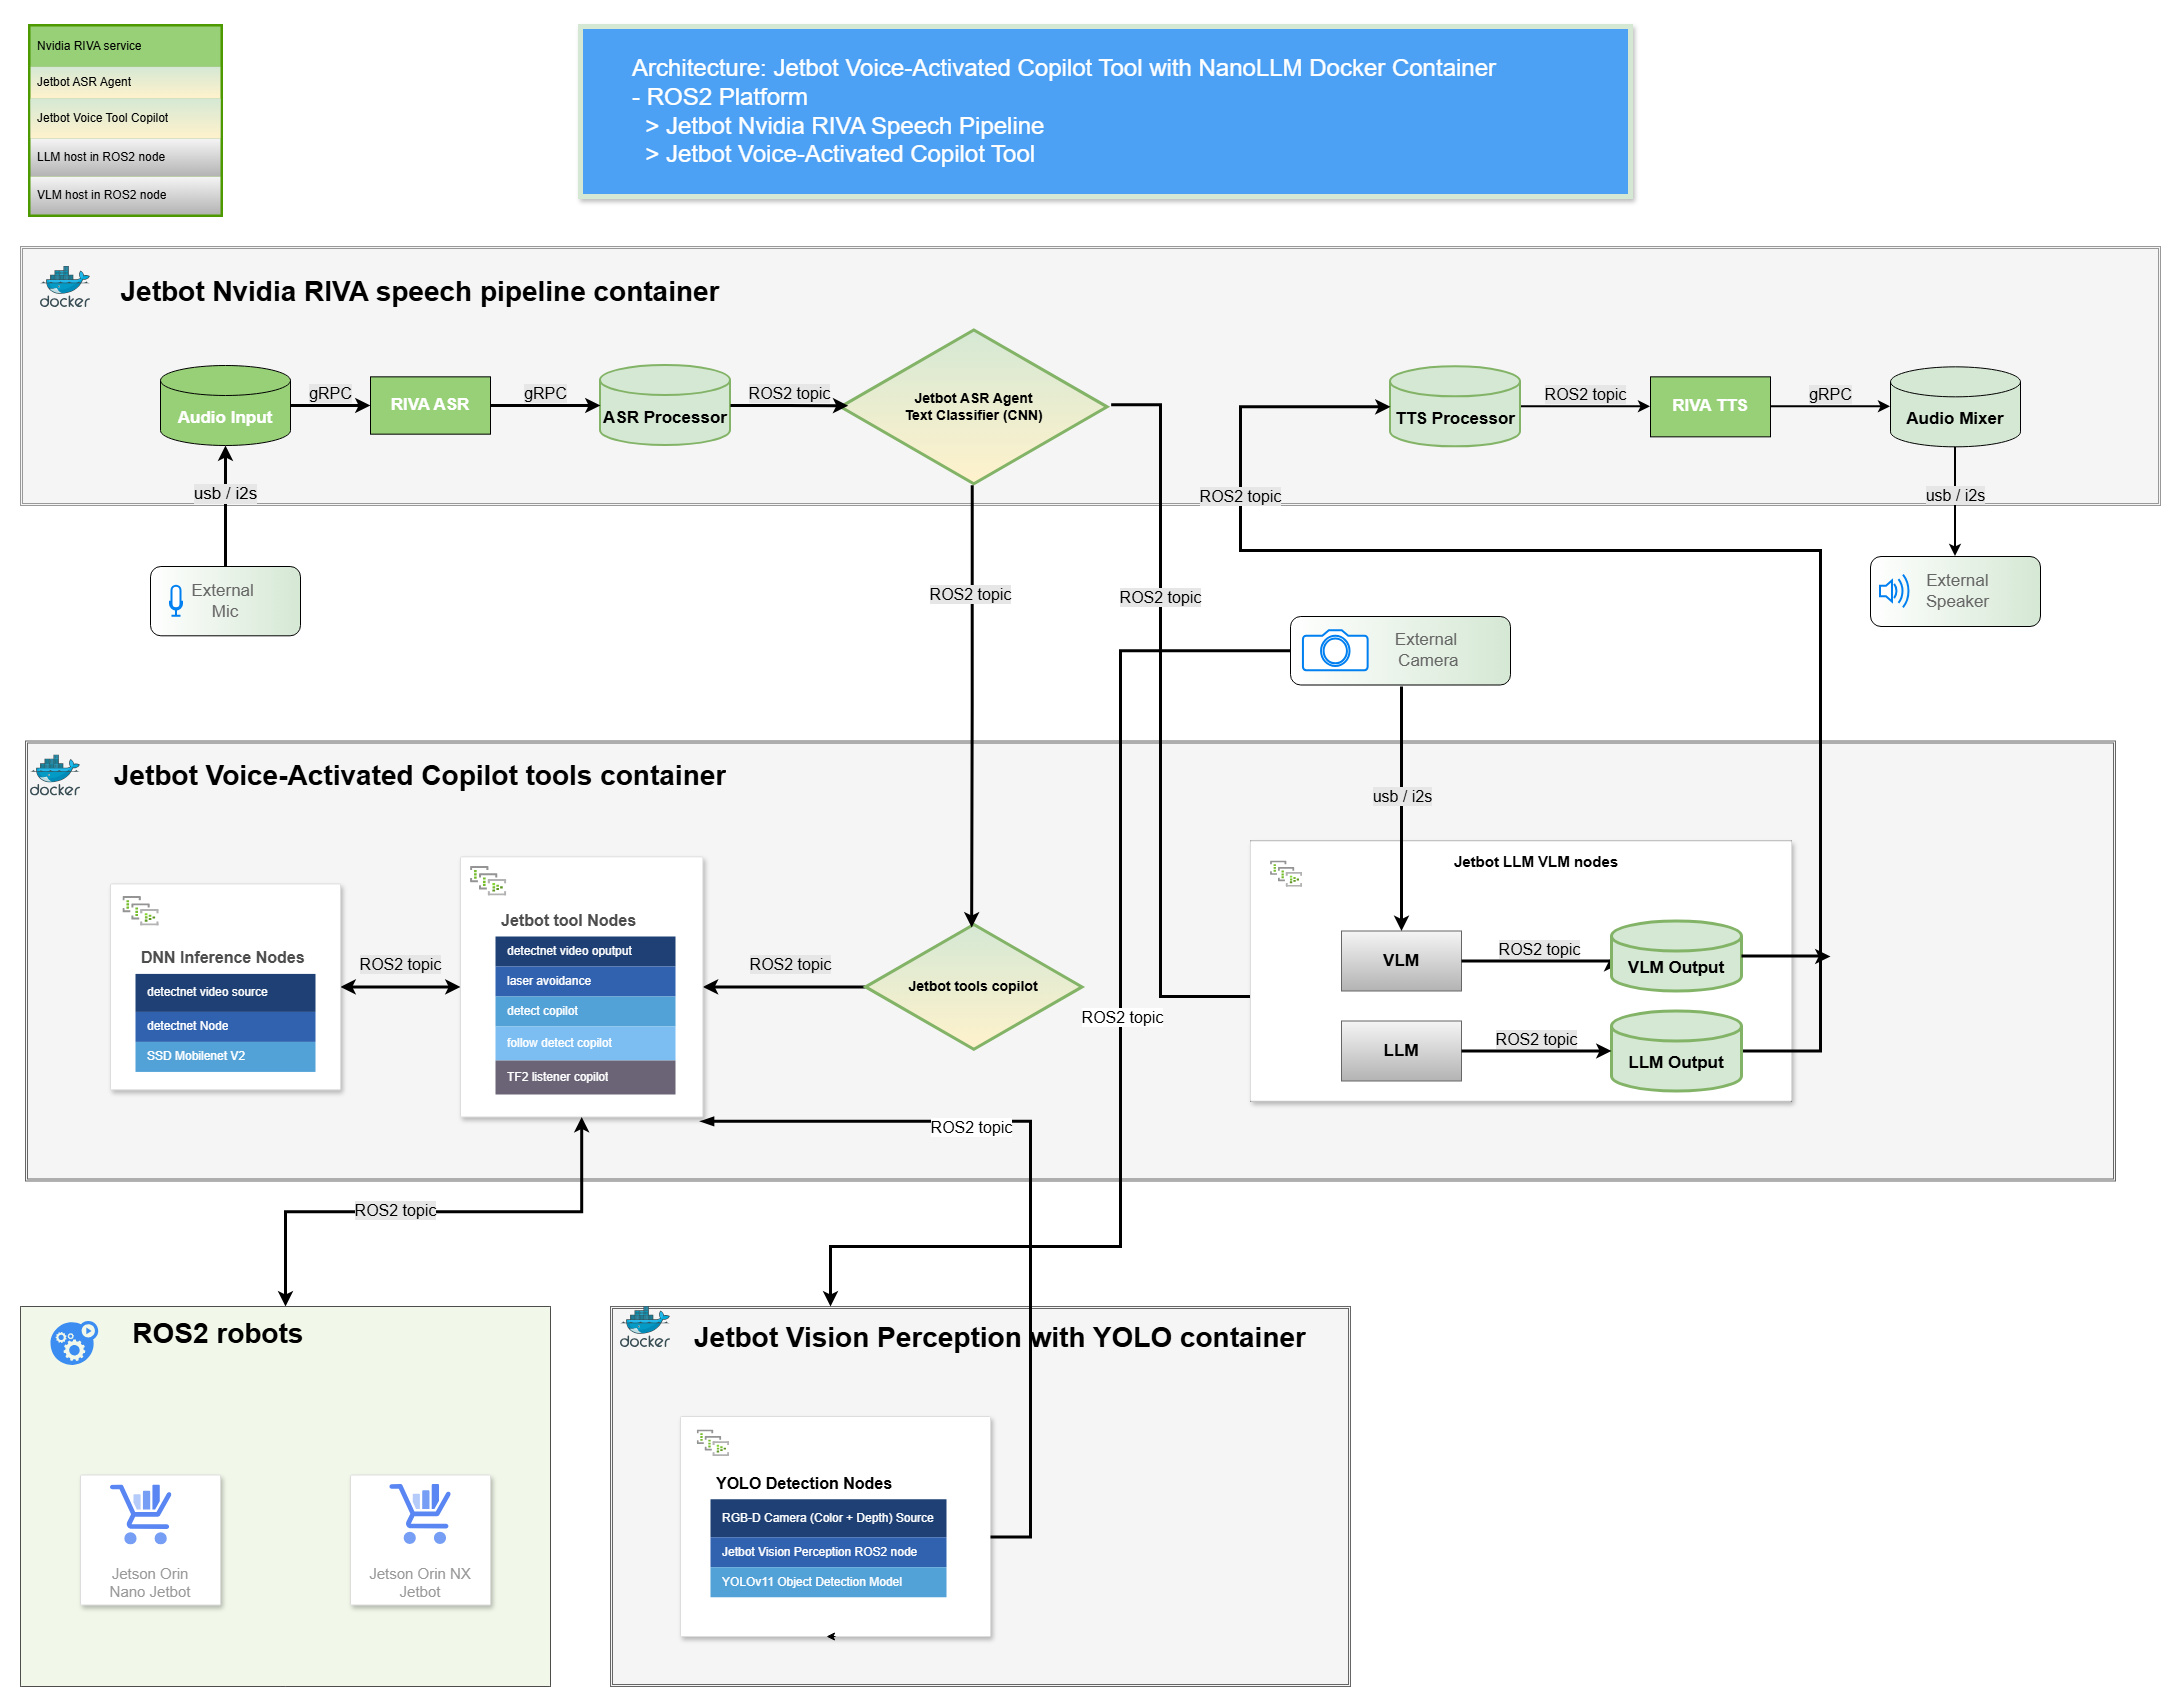
- Voice-Activated Copilot: Unleash the power of voice control for your ROS2 robot with Jetbot Voice-Activated Copilot Tools.
- Jetbot Tools Task Copilot (NEW in v2.1): Manage and coordinate all Jetbot Tools tasks through a unified ROS2 Action interface. The Task Copilot can start, stop, or interrupt long‑running operations, ensuring smooth cooperation between modules. When a voice‑activated command is received, it can automatically stop any currently running tasks and cleanly transition the robot into the newly requested action.
- Large Language Model (LLM) Chat: Empower your Jetbot to respond using LLM chat. By default, it utilizes the
meta-llama/Llama-2-7b-chat-hfmodel hosted in a ROS2 node. - Vision-Language Model (VLM) Robot Camera Image Description: Enable your Jetbot to describe images captured by its camera. By default, it employs the
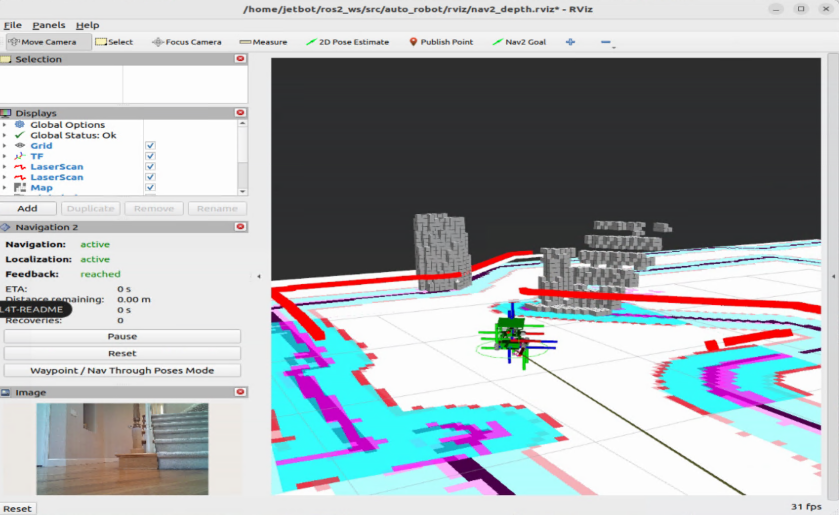
Efficient-Large-Model/VILA1.5-3bmodel hosted in a ROS2 node. - Depth‑Camera Vision Object Avoidance Self‑Driving (NEW in v2.1): Enable your robot to navigate autonomously using depth‑camera vision, allowing it to detect obstacles in 3D space and perform smooth, vision‑based avoidance behaviors.
- Lidar-Assisted Object Avoidance Self-Driving: Enable your robot to navigate autonomously and avoid obstacles using the lidar sensor.
- Real-Time Object Detection and Tracking: Allow your robot to detect objects using the SSD Mobilenet V2 model. You can also make your robot follow a specific object that it detects.
- Real-Time Object Detection and Distance Measurement (NEW in v2.1): Enable your robot to detect objects using the YOLOv11 vision system and measure their distance with the depth camera. You can also make your robot follow a selected object and automatically stop when it gets too close.
- NAV2 TF2 Position Tracking and Following: Allow your robot to track its own position and follow another Jetbot robot using the NAV2 TF2 framework.
Here is a brief overview of the jetbot tools design diagram/architecture
Setup
Jetbot tools source code and video demos:
-
Depth‑Camera Vision–Assisted Object Avoidance Self‑Driving (NEW in v2.1)
-
Real-time object detection and distance measurement (NEW in v2.1)
Requirements:
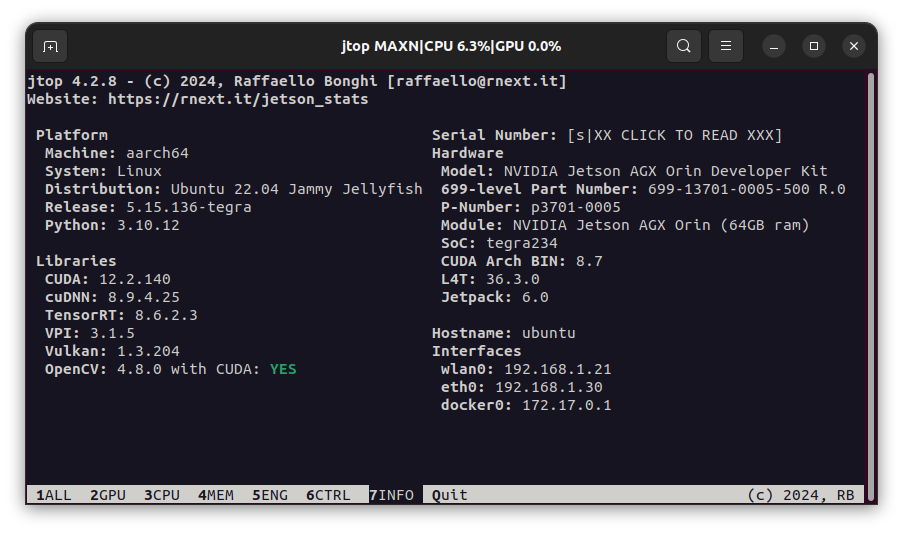
- Jetson Orin Nano or Jetson Orin NX:
- https://developer.nvidia.com/embedded/learn/get-started-jetson-agx-orin-devkit#what-youll-need
- ROS2 humble: https://docs.ros.org/en/humble/index.html
- NanoLLM docker container: https://github.com/dusty-nv/NanoLLM
- NanoLLM docker container for ROS2: https://github.com/NVIDIA-AI-IOT/ros2_nanollm
- Host Virtual Machine:
- Ubuntu 22.04.5 LTS (Jammy Jellyfish):https://releases.ubuntu.com/jammy/
- ROS2 humble: https://docs.ros.org/en/humble/index.html
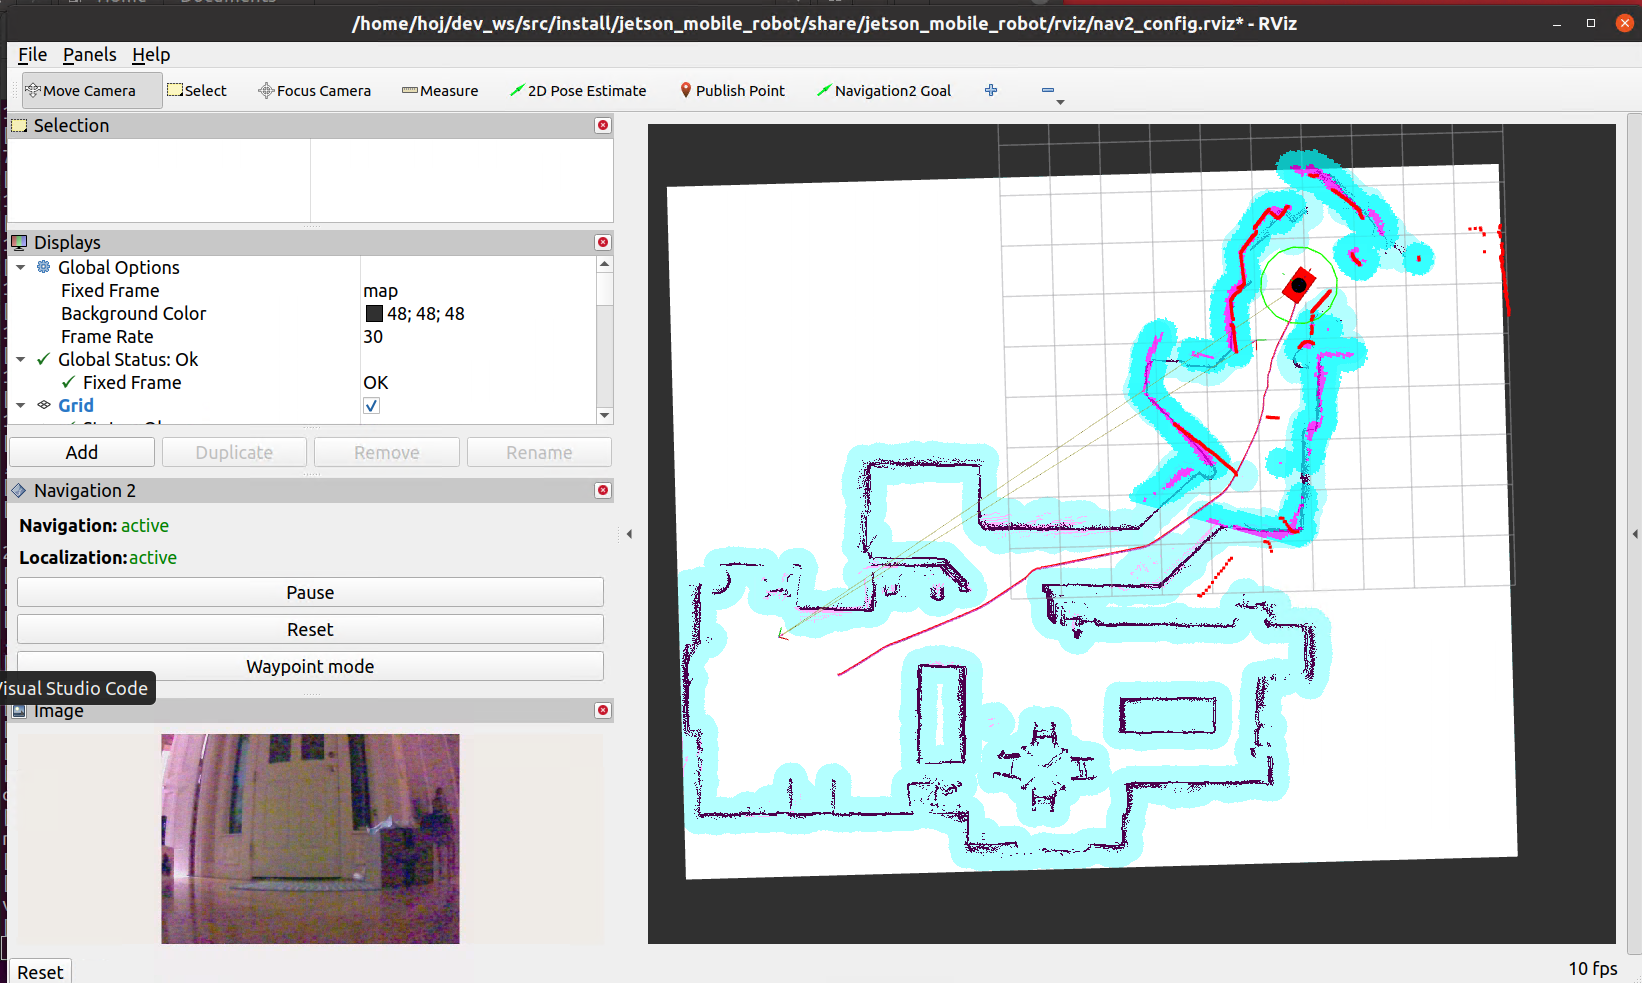
- NAV2 : https://wiki.ros.org/navigation
- Robot:
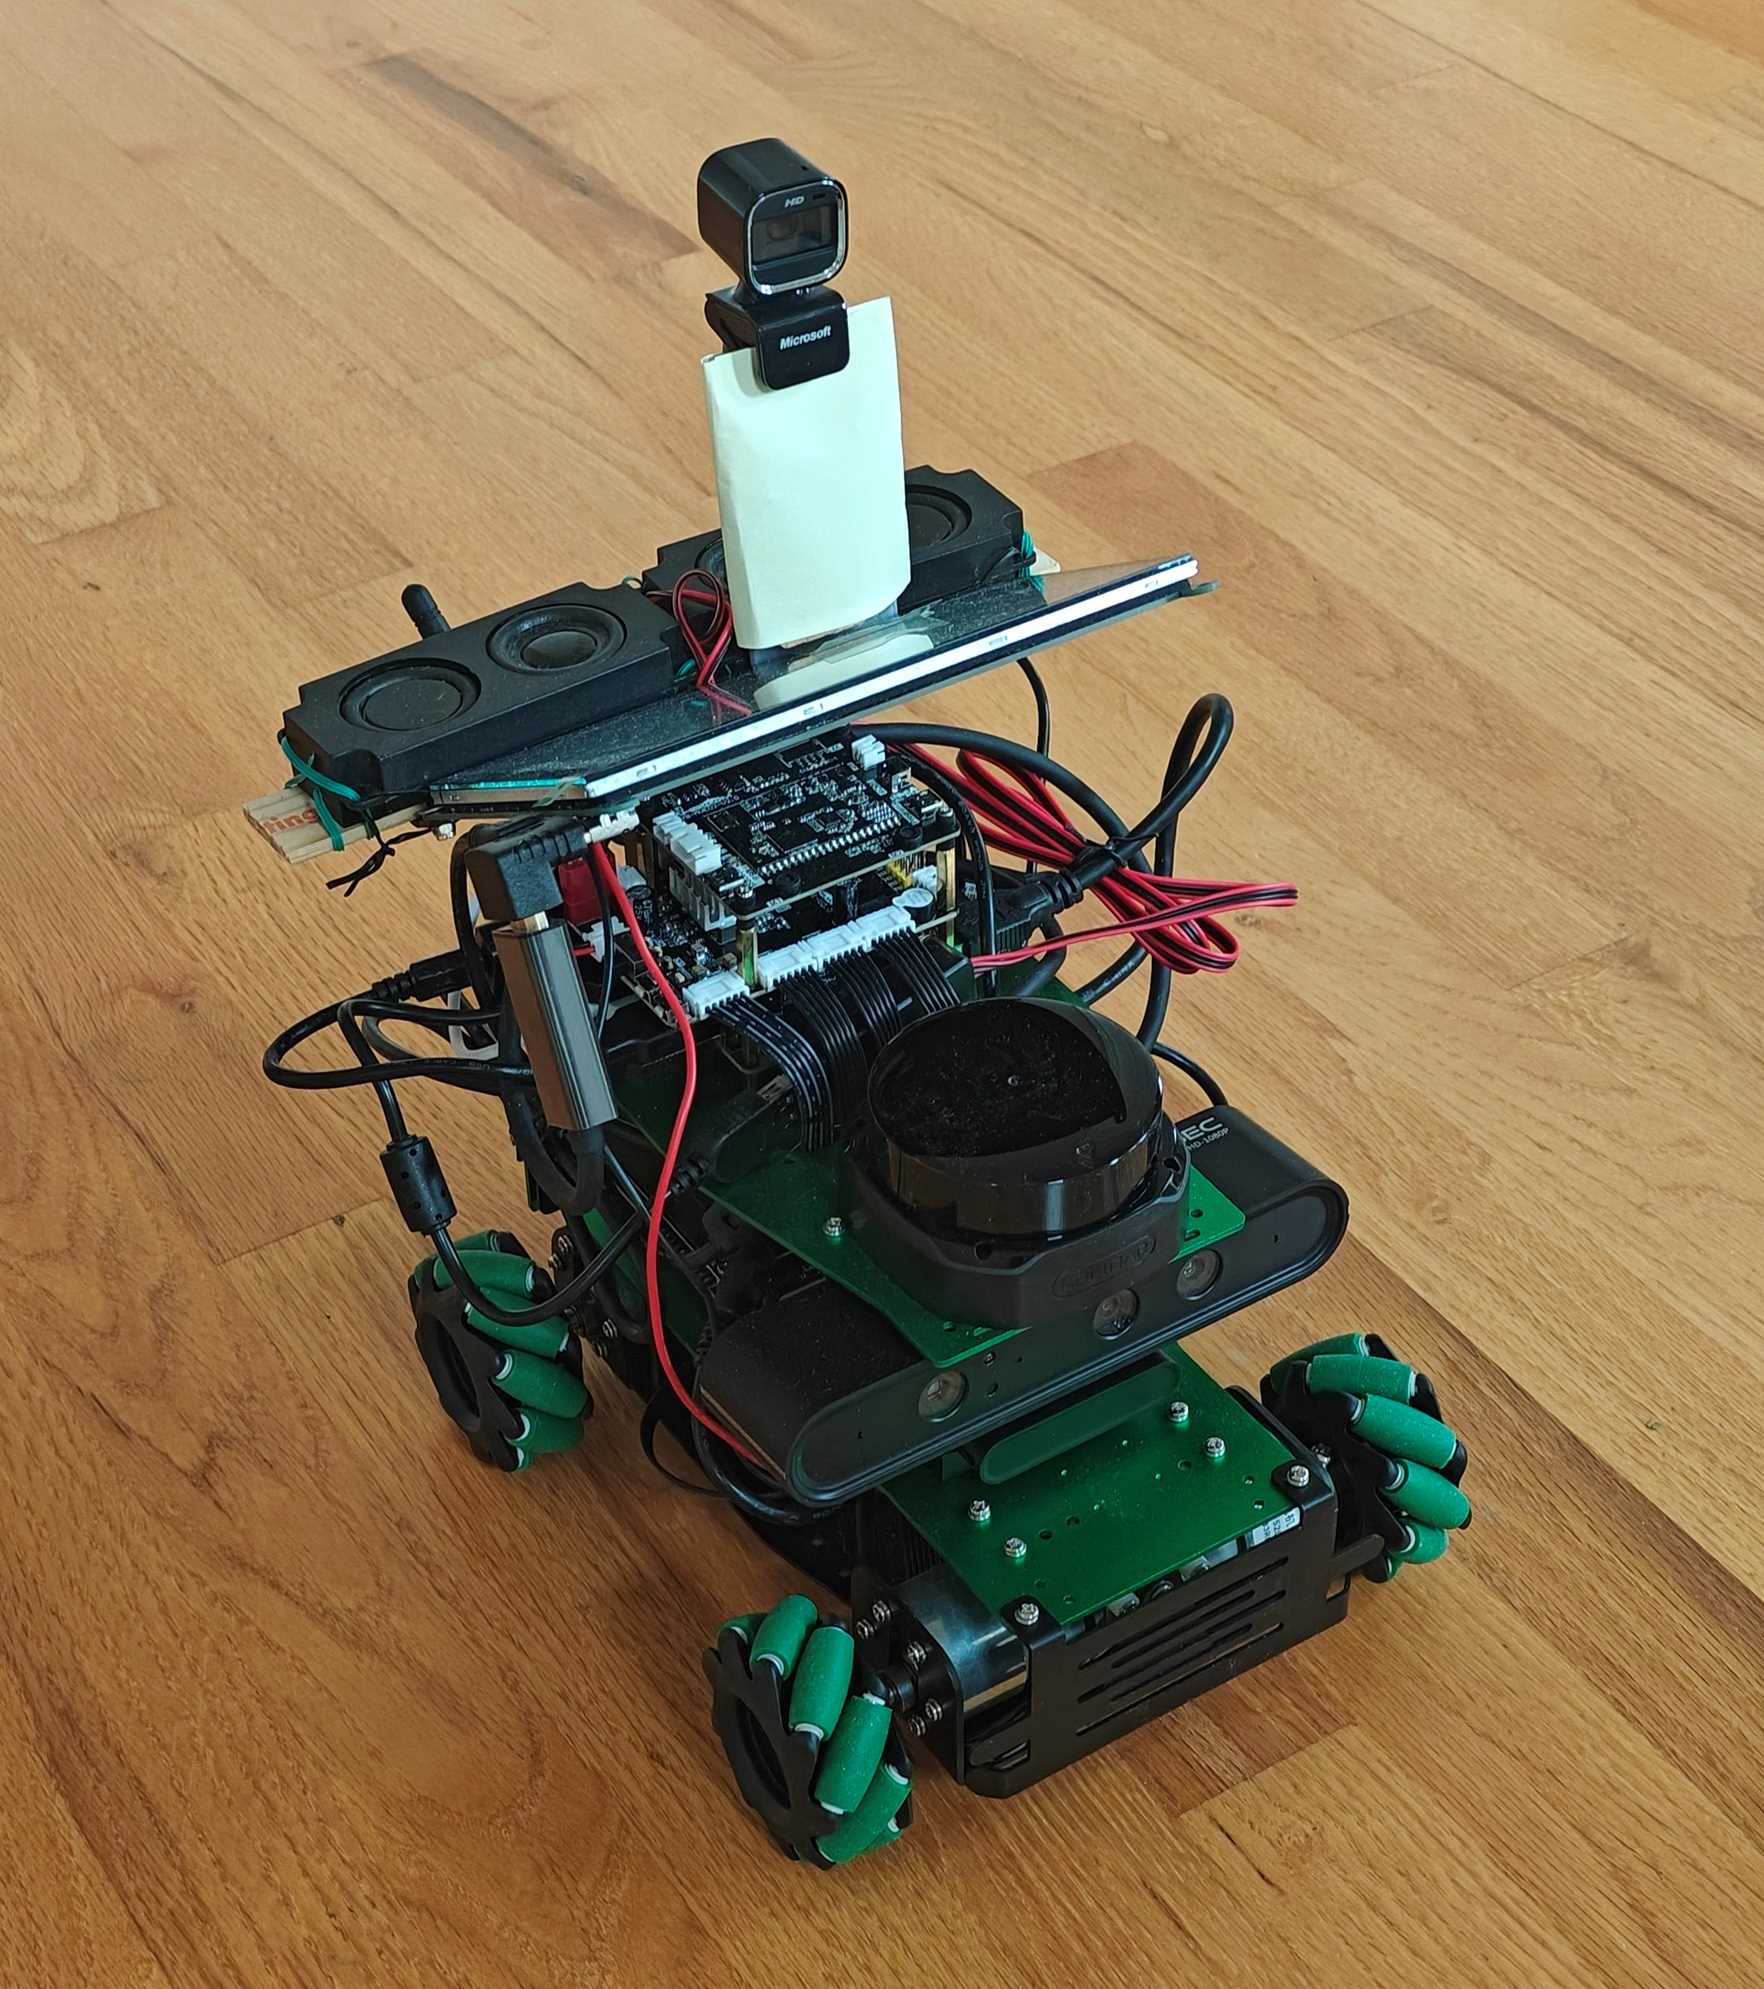
- Jetson Orin Jetbot: http://www.yahboom.net/study/ROSMASTER-X3
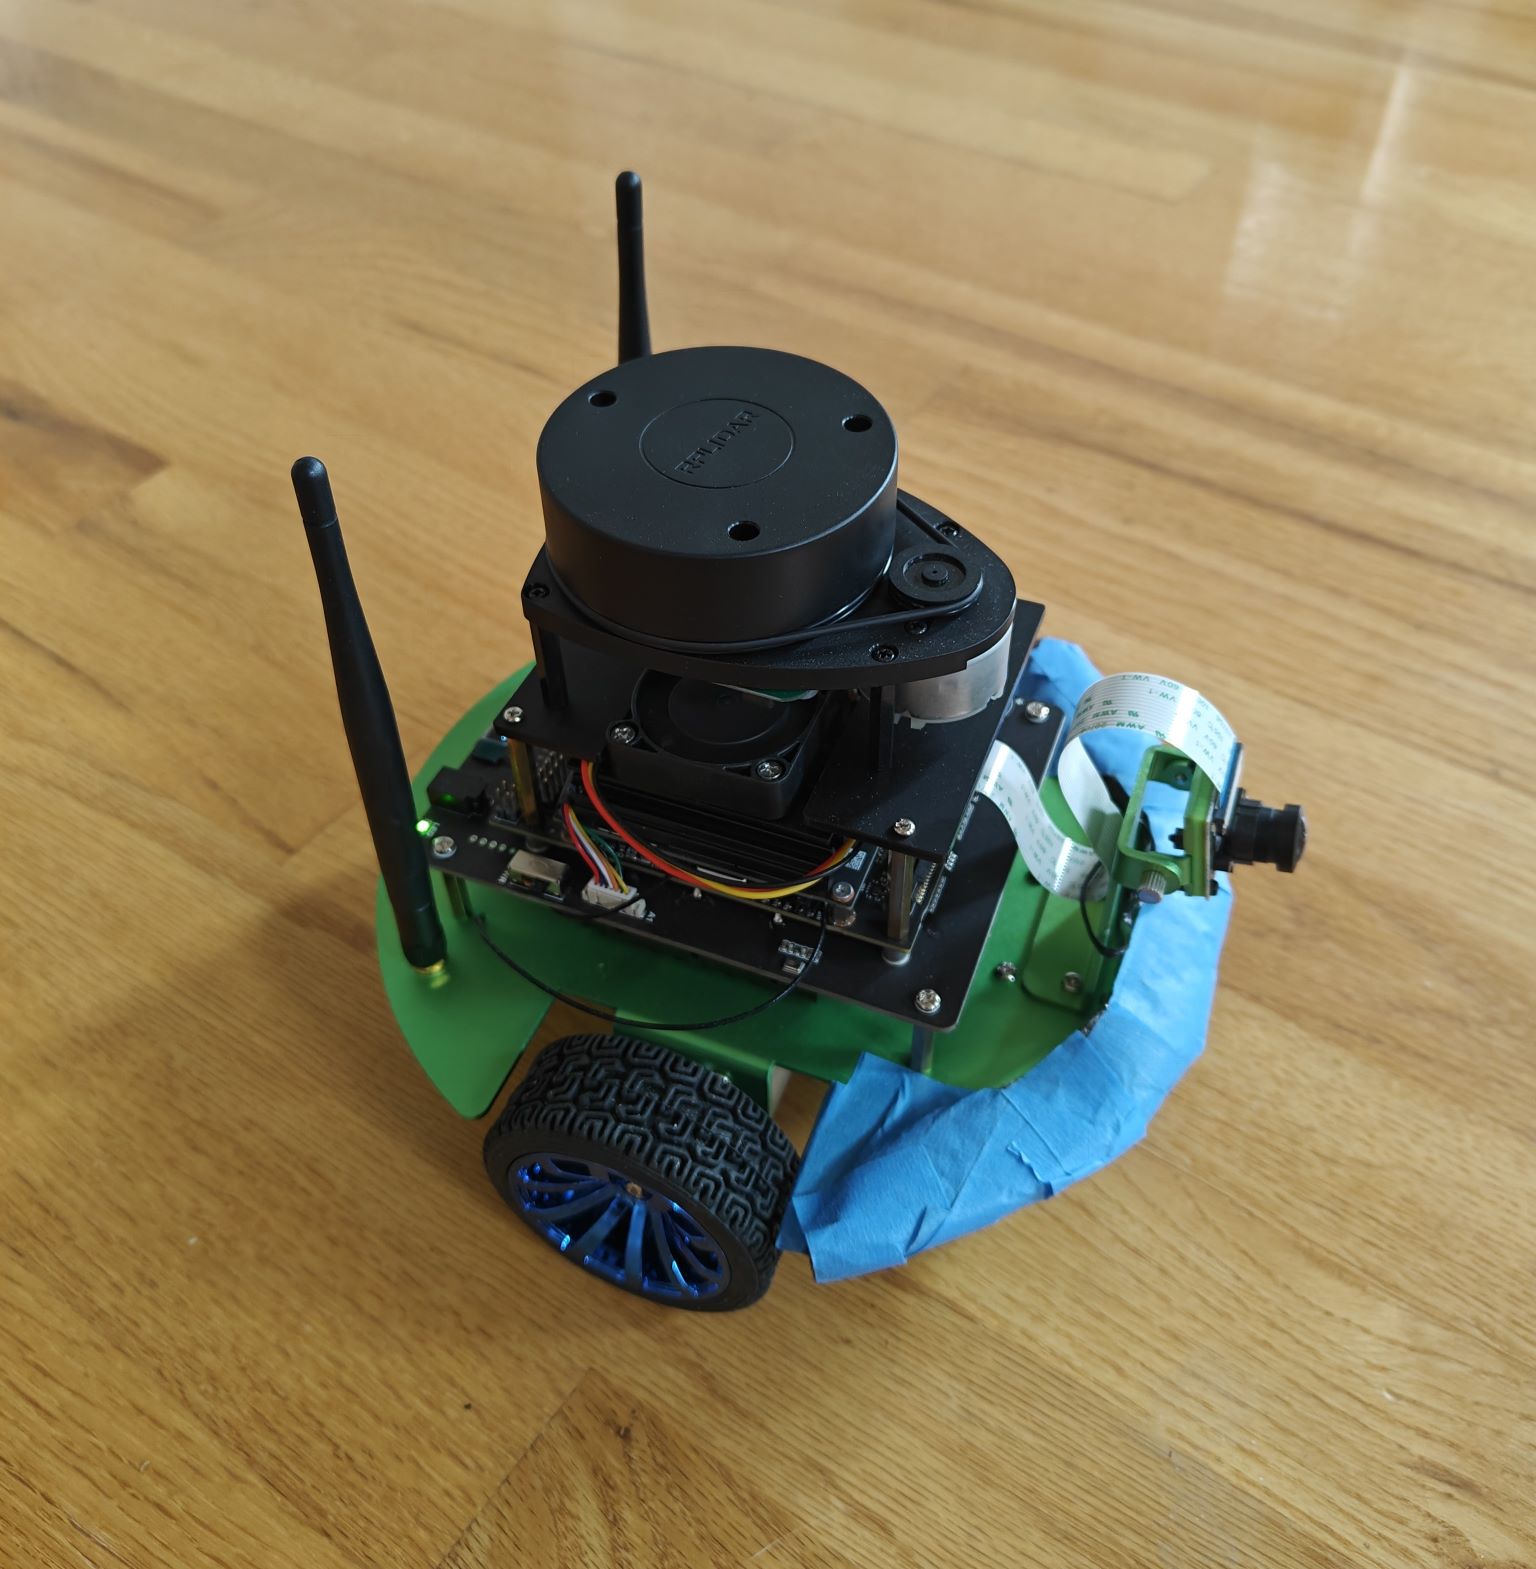
- Jetson Nano Jetbot: https://www.waveshare.com/wiki/JetBot_ROS_AI_Kit
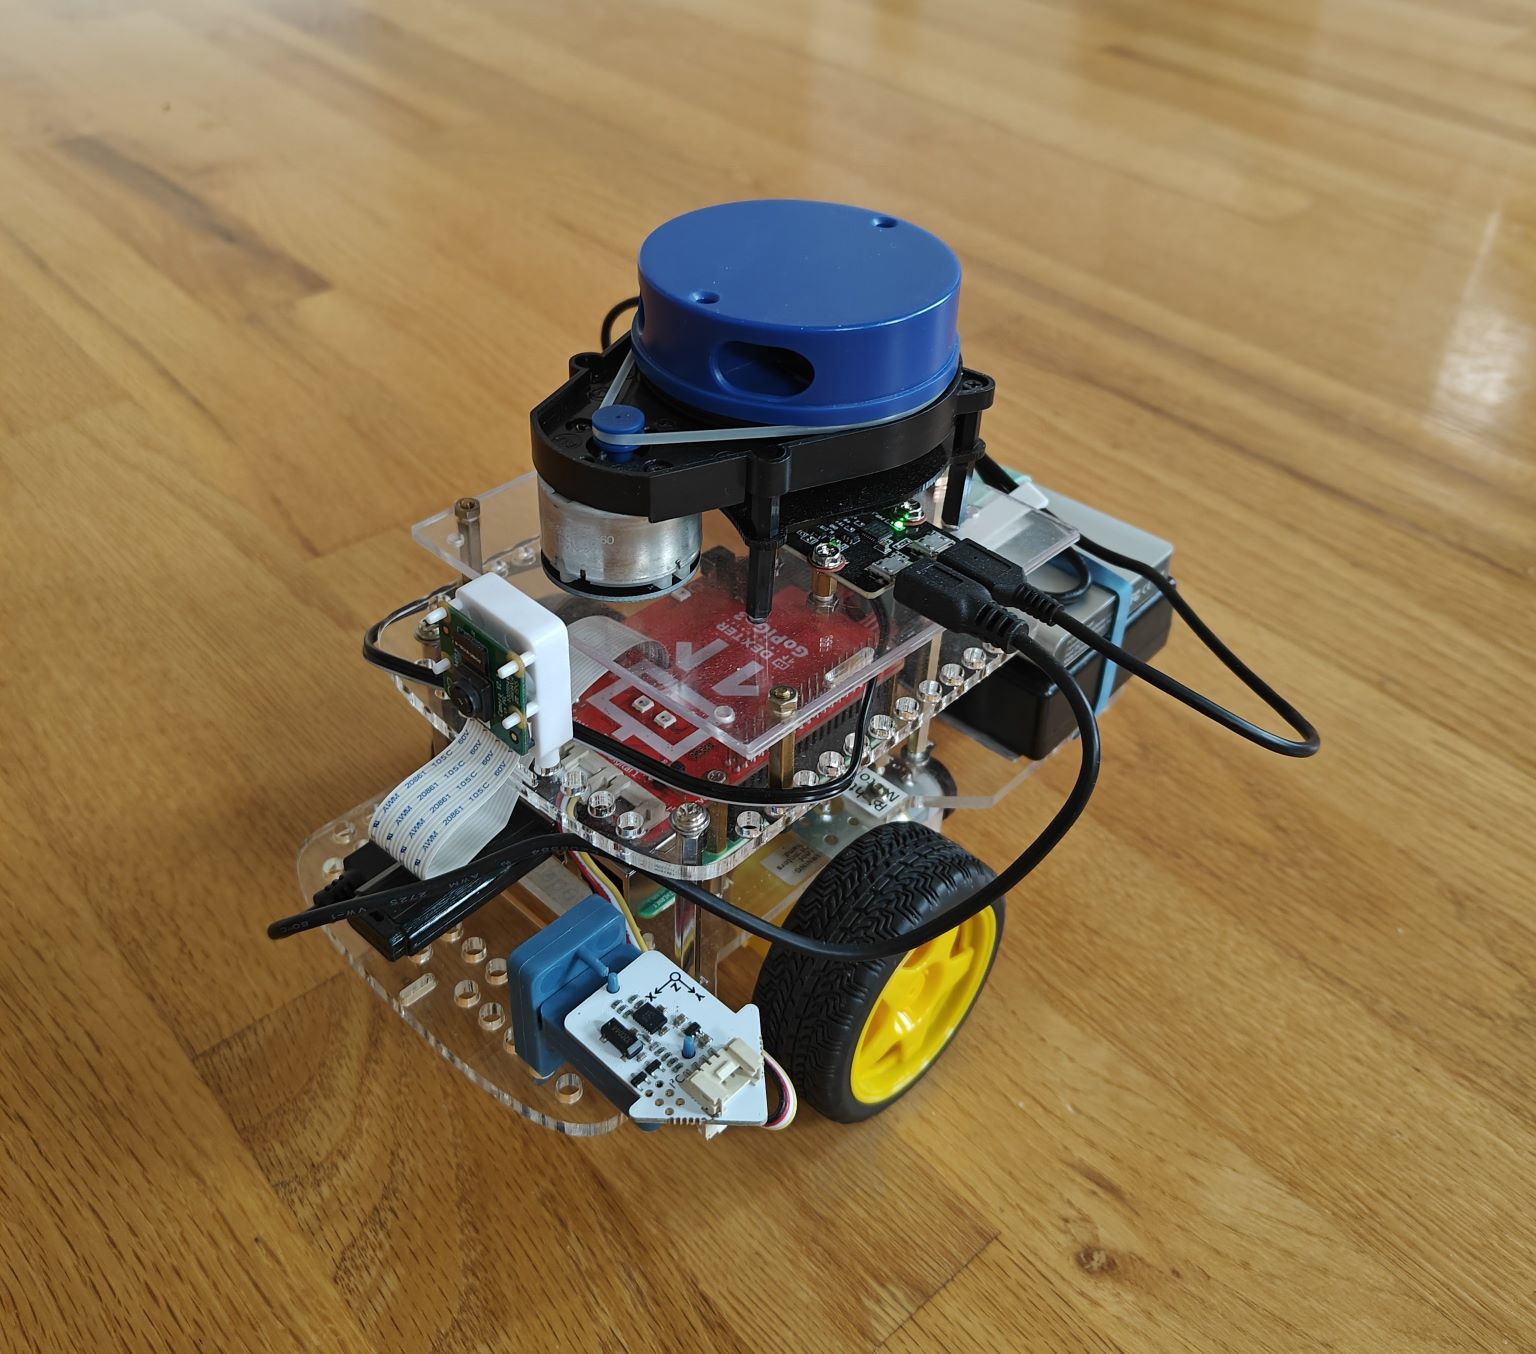
- GoPiGo3: https://www.dexterindustries.com/gopigo3/
References
- https://qengineering.eu/install-ubuntu-20.04-on-jetson-nano.html
- https://developer.nvidia.com/embedded/learn/get-started-jetson-agx-orin-devkit#what-youll-need
- https://docs.ros.org/en/humble/index.html
- https://docs.nav2.org/index.html
- https://github.com/dusty-nv/NanoLLM
- https://www.jetson-ai-lab.com/tutorial_llamaspeak.html
- https://www.jetson-ai-lab.com/archive/tutorial_ultralytics.html
- https://github.com/Jen-Hung-Ho/ros2_jetbot_voice
- https://github.com/Jen-Hung-Ho/jetbot_vision_perception
- https://automaticaddison.com/the-ultimate-guide-to-the-ros-2-navigation-stack/